
Vacuum Gripping for Robots: A Practical Guide to Reliable Suction Handling
Understand robot vacuum gripping, from effective suction area and loading to leakage, evacuation time, grip confirmation, release and complete-tool validation.
Practical guides to robot arms, end effectors, sensors and motion hardware.
Understand robot vacuum gripping, from effective suction area and loading to leakage, evacuation time, grip confirmation, release and complete-tool validation.
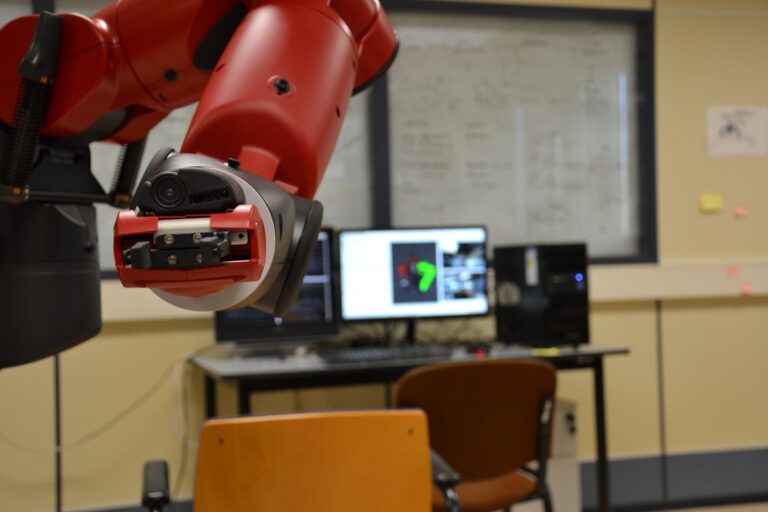
Compare mechanical, vacuum and soft robot grippers, then learn how payload, contact geometry, sensing and complete-cycle tests determine reliable handling.
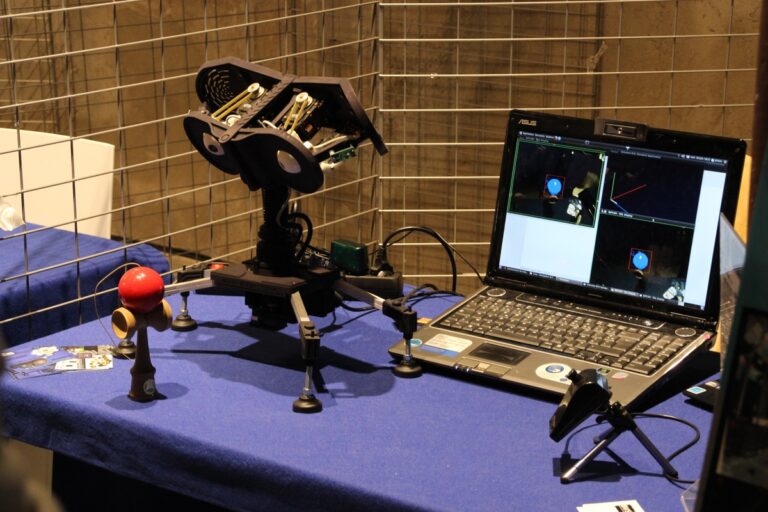
Understand how robot vision works, when to use 2D or 3D sensing, and how lighting, calibration and error testing turn images into reliable production decisions.

Compare manual and automatic robot tool changers, then evaluate loads, utilities, tool identity, calibration and dependable exchange recovery.
Understand robot force control, impedance and compliance, then plan sensing, contact behavior and validation around reliable physical results.
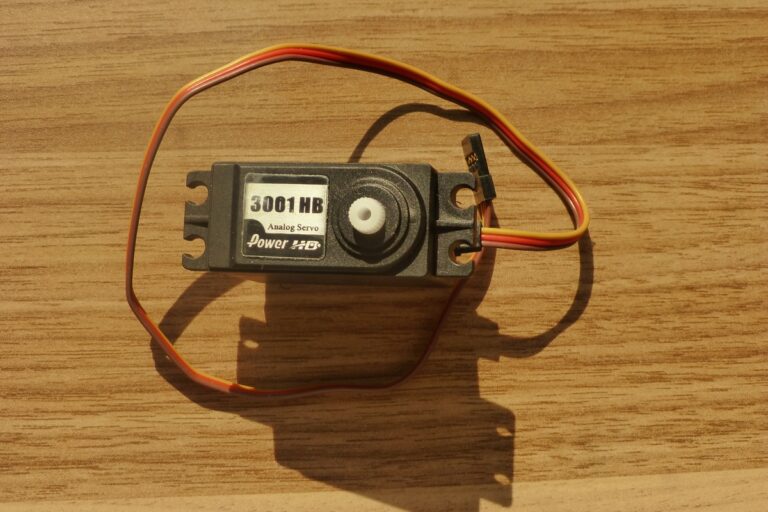
Learn how robot actuators combine motors, gearing, feedback and control, with practical load calculations and tests for speed, heat and repeated operation.

