Compare manual and automatic robot tool changers, then evaluate loads, utilities, tool identity, calibration and dependable exchange recovery.
A robot tool changer connects an arm to interchangeable end-effectors, allowing the same robot to use different grippers, process tools or inspection devices. Its value depends on changing that complete interface repeatably: mechanical attachment, utilities, tool identity and the controller configuration must agree.
This guide extends our gripper guide and machine-tending guide. It explains how to compare manual and automatic systems, check loads and design an exchange process that remains understandable after faults or maintenance.
Key Takeaways
Select a tool-changing system around the complete attached load, process forces and utility requirements, because a matching flange and a nominal payload figure do not establish compatibility.
Verify mechanical coupling, tool identity, supported utilities and the correct robot configuration as separate conditions before enabling the next operation.
Evaluate full exchange time, repeatable process quality and approved recovery under representative conditions, including contamination, unavailable tools and interrupted changes.
What a Tool Changer Does
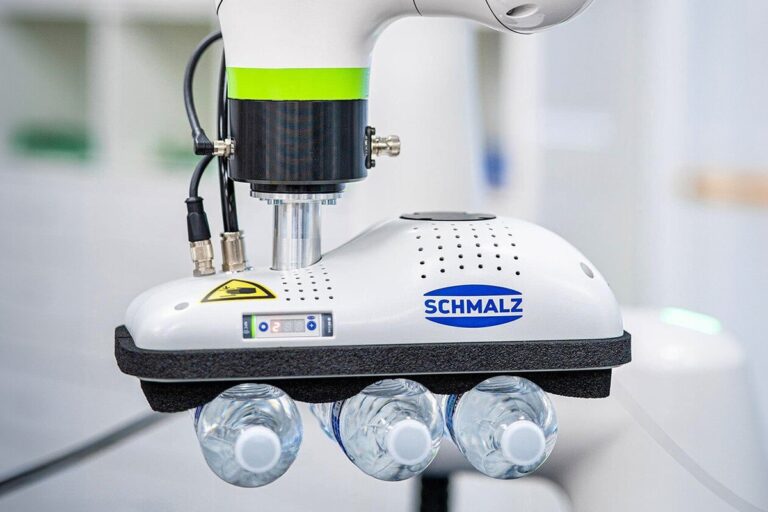
A typical system has a robot-side coupling and a mating tool-side coupling. Each exchangeable end-effector needs the appropriate interface, and unused tools need suitable storage.
The robot-side assembly is often called the master or quick-change head; the tool-side assembly may be called the tool plate or adapter. Terminology varies, so identify the actual components in the supplier’s drawings.
A robotic tool changer is different from a CNC machine’s spindle tool magazine. The former changes an arm’s end-effector; the latter changes cutting tools inside a machine. The applications can coexist in a tending cell but have different interfaces and responsibilities.
Start by listing the operations that need different tooling. An adjustable gripper or a combined tool may sometimes satisfy the task without exchanging the complete end-effector.
Manual, Automatic or Multiple Tools
Approach
Potential fit
What to evaluate
Manual quick change
Planned product changes with operator access
Approved handling, connection checks and setup time
Automatic change
Repeated tool exchanges during an automatic sequence
Tool storage, identity, coupling confirmation and recovery
Combined end-effector
Several functions carried together
Added mass, bulk, reach and interference
Adjustable tooling
Variations within a compatible tool family
Adjustment range, repeatability and process limitations
Automatic changing introduces a new process rather than eliminating setup engineering. It can reduce operator involvement when exchanges are frequent, but adds hardware, storage locations and states that must be maintained.
Compare options using the same production requirement. A manual change between long batches has different economics from changing tools several times for every finished part.
Assess Mass, Moments and Stack Height
Count the robot-side coupling, tool-side coupling, adapters, attached tool, accessories and workpiece. Include everything that moves with the wrist.
Mass alone is insufficient. A tool’s distance from the flange changes the loading, and process forces can add moments even when the robot is stationary.
SCHUNK’s technical data lists handling weight, directional moments, repeat accuracy and operating conditions separately. This illustrates why a single handling-weight number cannot replace a complete selection check.
For a simple static example, a 5 kg mass located 0.2 meters horizontally from an interface creates a gravitational moment of about 9.81 newton-meters. That calculation excludes acceleration and process forces; it is not a sizing recommendation.
Check both the coupling and robot against the complete application. Our arm selection guide explains why carried geometry and usable workspace matter alongside nominal capacity.
Map Every Required Utility
An end-effector may require compressed air, vacuum, electrical power, discrete signals, industrial communication, fluids or a combination. Specify what must cross the interface and what remains permanently connected.
List flow, pressure, current, voltage, connector type and communication needs using the applicable supplier documentation. Matching the number of ports does not establish adequate performance.
Also define the disconnected state. A tool left in its stand may need a particular energy state, protected connectors or retained workpiece handling. Those requirements depend on the tool and application.
Inspect cable and hose behavior across the full robot motion and exchange route. A connection that works on a bench can still impose load, snag or interfere with adjacent tools once installed.
Separate Coupling From Tool Readiness
A locked coupling does not automatically mean the correct tool is present, its utilities are functioning or its software is ready. Treat these as separate conditions with explicit meanings.
For example, a cell might establish that the interface is coupled, identify a particular gripper, confirm its communication and load the approved recipe before allowing the next task. The actual signals and sequence must follow the selected equipment’s supported design.
Our integration guide explains why commands, acknowledgments and physical results need different states. A request to lock is not the same evidence as a verified accepted coupling.
Design timeouts and contradictory-signal responses before commissioning. An uncertain state should be resolved through the approved recovery process rather than treated as a normal tool attachment.
Identify the Tool and Load Its Configuration
Give every interchangeable assembly a controlled identity. Connect that identity to its allowed jobs, tool center point, payload model, geometry, process parameters and relevant maintenance record.
A tool may physically fit while being wrong for the task. A different finger set, camera mount or process head can change clearances and the location where work occurs.
Universal Robots’ configuration tutorials cover tool center point, orientation, payload and center of gravity. The applicable robot’s own documentation determines which settings must change for an exchanged assembly.
Our calibration guide explains how those references relate to physical tooling. Do not confuse repeatable docking with a correct tool-center calibration.
Design the Tool Stand as Part of the System
The stand supports stored tools and provides a repeatable exchange location. It must suit the tool’s mass, geometry, approach direction and the forces expected during its approved docking process.
Check clearance for the entire assembly, including cables, open fingers and neighboring tools. Reserve access for inspection and replacement without introducing an awkward recovery route.
Provide a defined response when a storage position is occupied, empty or obstructed unexpectedly. An empty location in software does not establish that the physical stand is clear.
Protect the interface from the contamination expected in the process. Dust, chips, coolant or adhesive can affect more than appearance, especially where mating surfaces and utility contacts must remain dependable.
Measure the Whole Exchange
A supplier’s coupling time describes only part of an automatic tool change. Include travel to storage, placing the previous tool, releasing, withdrawing, approaching the next tool, coupling, verification and returning to work.
For an illustrative comparison, suppose the full automatic sequence takes 18 seconds and an approved manual change takes 90 seconds. At 40 changes per shift, the modeled difference is 2,880 seconds, or 48 minutes.
That figure is not a guaranteed production gain or cash saving. Determine whether the saved time lies on the critical path, whether it frees usable operator capacity and what additional maintenance the automatic system requires.
Use our ROI guide to connect the complete installed cost with realizable benefits. Include spare adapters, tool stands, interface modules, engineering and qualification.
Validate Repeatability at the Process
Interface repeatability describes a property under specified conditions. The finished task also depends on robot positioning, tool calibration, assembly stiffness, loading and the workpiece reference.
For a measurement tool, evaluate the resulting measurement after repeated exchanges. For a process tool, evaluate the finished work. A repeatable coupling alone does not establish acceptable output.
Include representative orientations and loads. A long tool can turn a small angular variation into a meaningful displacement at its working end.
Record the test conditions and complete assembly. Changing an adapter, extending a tool or replacing a locating element may require review even if the coupling model remains unchanged.
Understand Retention and Failure Behavior
A product’s retention feature needs to be understood in its documented operating context. Preventing an immediate tool release is different from maintaining normal rigidity or positioning performance.
ATI’s QC-46 manual states that its fail-safe condition can retain the tool after loss of locking air, while positional accuracy is not maintained and normal operation must not continue in that condition. This is product-specific behavior, not a rule for every changer.
Have the supplier define the accepted response to lost utilities, unavailable sensing and incomplete engagement for the selected model. Avoid transferring recovery assumptions from a different mechanism.
Assess retained workpieces and stored energy as well as the coupling itself. Keeping the tool attached does not automatically keep the product in its gripper or make the surrounding process ready for intervention.
Recover an Interrupted Change Deliberately
After an interruption, establish the physical relationship between the robot, tool and stand. The controller may have stopped between placing a tool and recording its release.
Do not resolve uncertainty by simply repeating the last command or restarting at the next program line. The correct action depends on whether the tool is supported, attached, identified and in a permitted energy state.
Define who may intervene, what evidence is required and how the accepted state is restored. Use the manufacturer’s procedures and the completed application’s approved recovery plan.
Our safety guide covers responsibilities across production, setup and maintenance. A convenient quick-release feature does not establish safe access to the complete robot system.
Qualify the Complete Tool Set
Test every approved tool rather than one convenient representative. Include legitimate extremes of mass, length, utility demand and storage position.
Run repeated exchanges within a representative production sequence. Check process quality, identification, utility readiness, exchange duration and interventions together.
Plan approved tests of missing tools, an occupied stand position and interrupted exchange states. Conduct them under controlled commissioning conditions without bypassing protections or deliberately creating hazardous releases.
Save the accepted versions of tool assemblies, robot configurations, recipes and interface logic. Review the affected tests after changes, not only after a visible failure.
Maintain the Interface and Its Records
Inspect and service mating surfaces, locating elements, retention mechanisms and utility connections according to the specific equipment documentation. Do not apply generic lubrication or cleaning instructions to an unfamiliar coupling.
Trend exchange faults and process drift alongside usage. Repeated recoveries at one stand location may indicate a locating problem; errors across all tools may suggest a shared interface or control issue.
Our maintenance guide explains how consistent records support diagnosis. Keep replacement assemblies and calibration records aligned with the identities used in production.
A useful tool-changing system makes the robot flexible while preserving a known, verified configuration. Select the interface, storage, utilities and recovery process together, then judge the result by sustained acceptable work.
Frequently Asked Questions
What is a robot tool changer?
It is an interface that allows a robot arm to exchange end-effectors, with mechanical attachment and, where provided, utility connections.
Is automatic changing always better than manual changing?
No. Compare exchange frequency, operator access, complete change time, system complexity and the benefits the operation can actually use.
Does the changer’s payload rating settle selection?
No. Check complete attached mass, directional forces and moments, tool geometry, movement and the robot’s limits.
Does a locked signal prove that the tool is ready?
No. Tool identity, utility readiness and the correct controller configuration may require separate confirmation.
Can a changer’s repeatability replace tool calibration?
No. Repeatable coupling and an accurate tool-center reference are different requirements, and both can affect the finished process.
What should an automatic tool-change pilot prove?
It should verify every approved assembly, complete exchange time, process quality and approved recovery under representative operating conditions.