
Robot Fleet Management: Tasks, Traffic and Reliable AMR Operations
Learn how robot fleet management connects dispatch, traffic, charging and recovery, with practical capacity examples, interface checks and pilot validation.
Access a structured collection of in-depth guides covering the full spectrum of robotics, artificial intelligence, and automation. This section aggregates evergreen, research-driven explainers, industry primers, technology breakdowns, and strategic overviews that clarify how intelligent machines are designed, deployed, and commercialized. From humanoid robotics and industrial automation to physical AI, autonomous systems, and foundational machine learning models, each guide is built to provide durable context rather than time-sensitive updates. Designed for professionals, engineers, investors, and informed readers, the Guides page functions as a centralized knowledge layer within RobotsBeat. It organizes scalable, long-form analysis that complements news coverage and glossary references.
Learn how robot fleet management connects dispatch, traffic, charging and recovery, with practical capacity examples, interface checks and pilot validation.
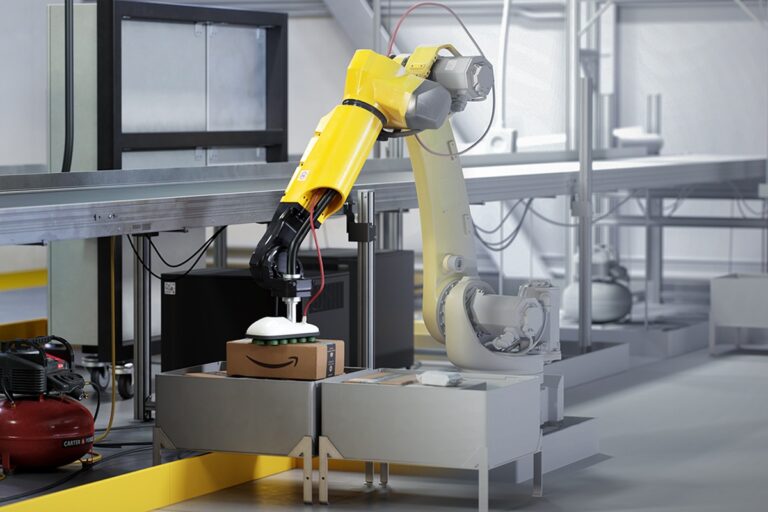
Learn what makes a robotics digital twin useful, how it differs from a simulation, and how to define data, validate predictions and maintain a trustworthy model.
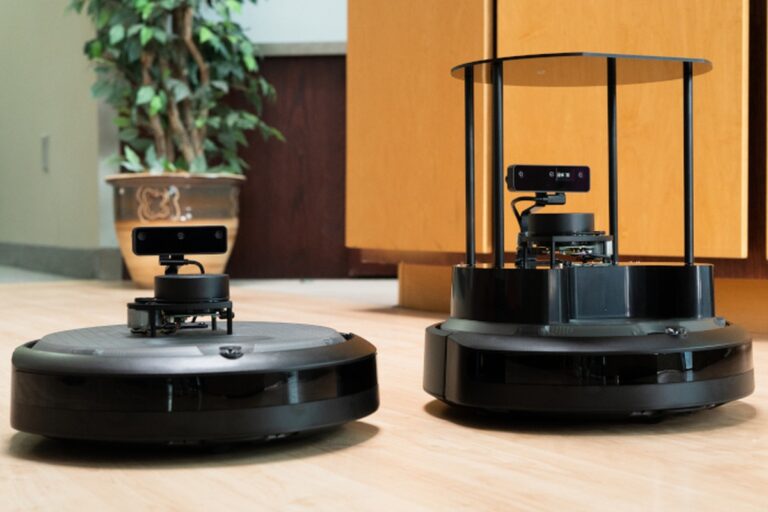
Learn how ROS 2 connects robot software through nodes, topics, services and actions, with practical guidance on frames, debugging, simulation and production readiness.
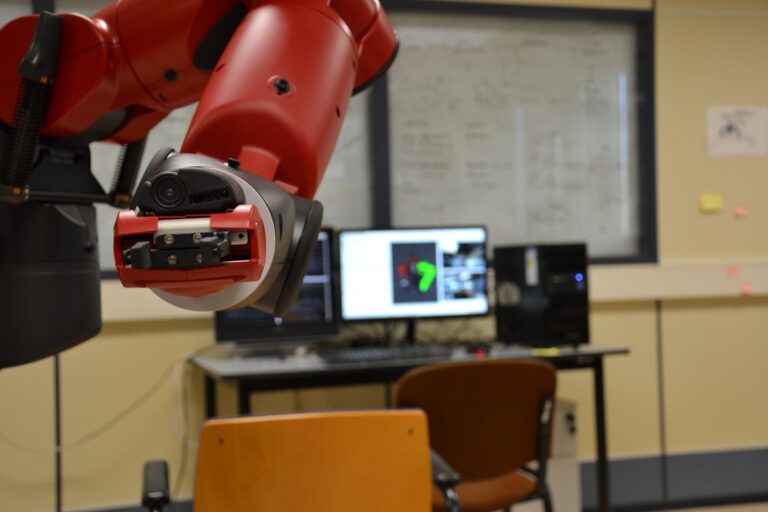
Compare mechanical, vacuum and soft robot grippers, then learn how payload, contact geometry, sensing and complete-cycle tests determine reliable handling.
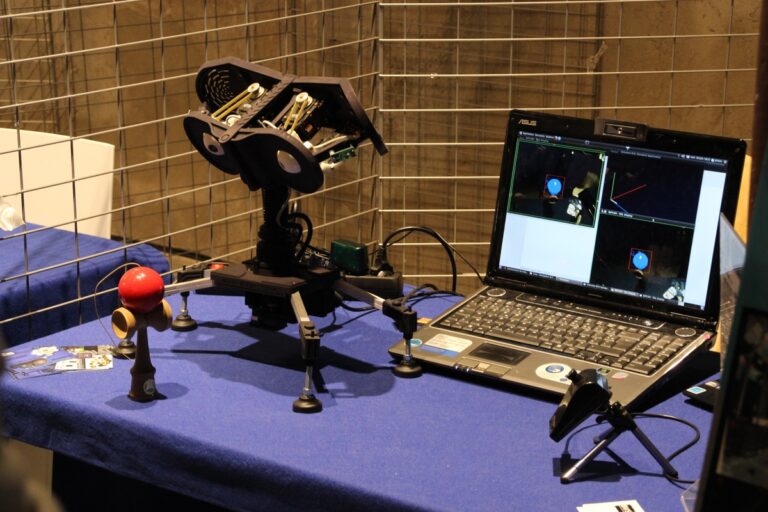
Understand how robot vision works, when to use 2D or 3D sensing, and how lighting, calibration and error testing turn images into reliable production decisions.
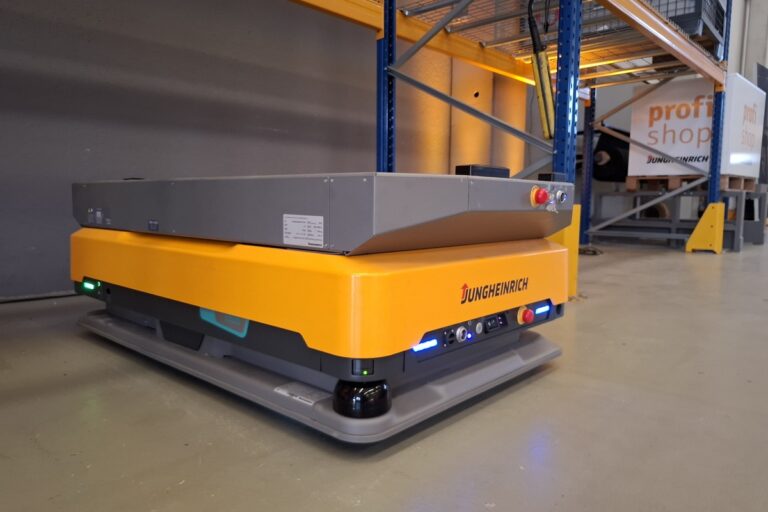
Learn how autonomous mobile robots move materials, how AMRs compare with AGVs, and how to evaluate routes, handoffs, fleet capacity and deployment costs.
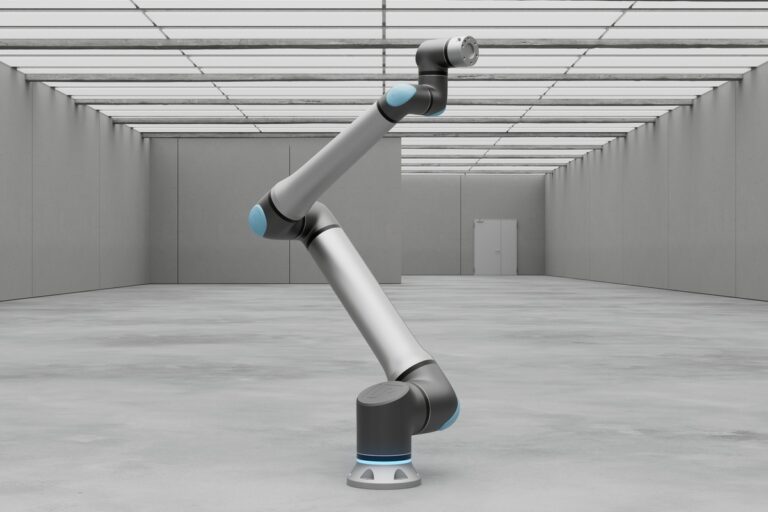
Learn how collaborative robots work, where cobots fit, and how to evaluate safety, tooling, performance and costs before deploying a complete workstation.
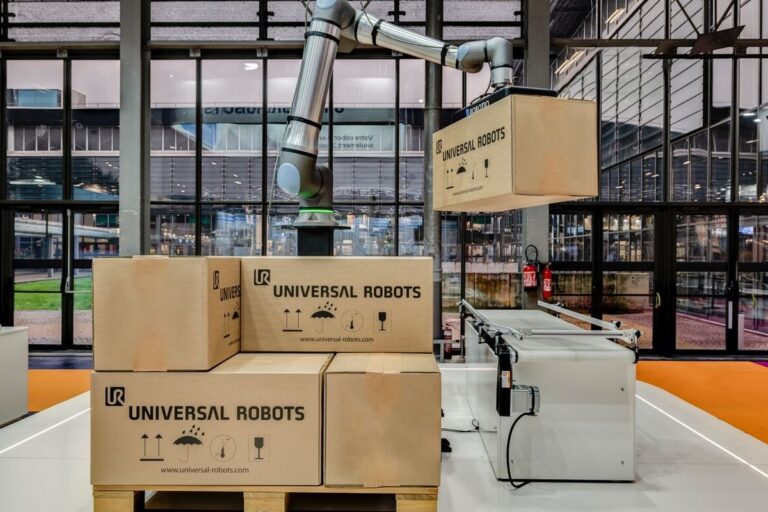
Learn how robotic automation works, where robots fit, and how to plan deployment, assess costs, validate safety and measure real operating results.
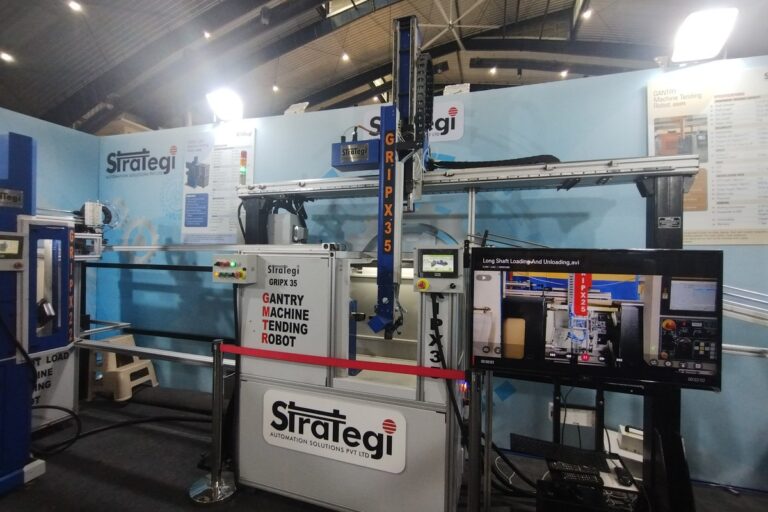
Learn how to plan robot machine tending for CNC equipment, from part presentation and workholding to cycle time, inspection and dependable unattended operation.

