Key Notes
- CoreWeave’s Physical AI Launchables packages robot simulation and training tools into tested cloud templates announced on October 21.
- The initial catalog includes Isaac Sim, CARLA, MuJoCo, AlpaSim and Cosmos 3, with blank templates available for custom workloads.
- Account-managed access is available now, while template execution checks do not replace engineering validation of robot performance or safety.
CoreWeave has launched Physical AI Launchables, a catalog of tested cloud workflows for robotics, autonomous vehicles and simulation. Announced at GTC Berlin on October 21, the service packages existing engineering tools into templates that teams can configure and run without rebuilding the underlying environment.
The announcement addresses setup work around experiments: deploying software, connecting storage, assigning compute and collecting results. CoreWeave provides those configurations while engineers supply their own scenes, data and evaluation criteria.
Five Tools Cover Training and Evaluation
The launch catalog supports NVIDIA Isaac Sim, CARLA, MuJoCo, NVIDIA AlpaSim and NVIDIA Cosmos 3. Together, the tools cover robot simulation, driving scenarios, policy training and synthetic data generation rather than one universal robotics application.
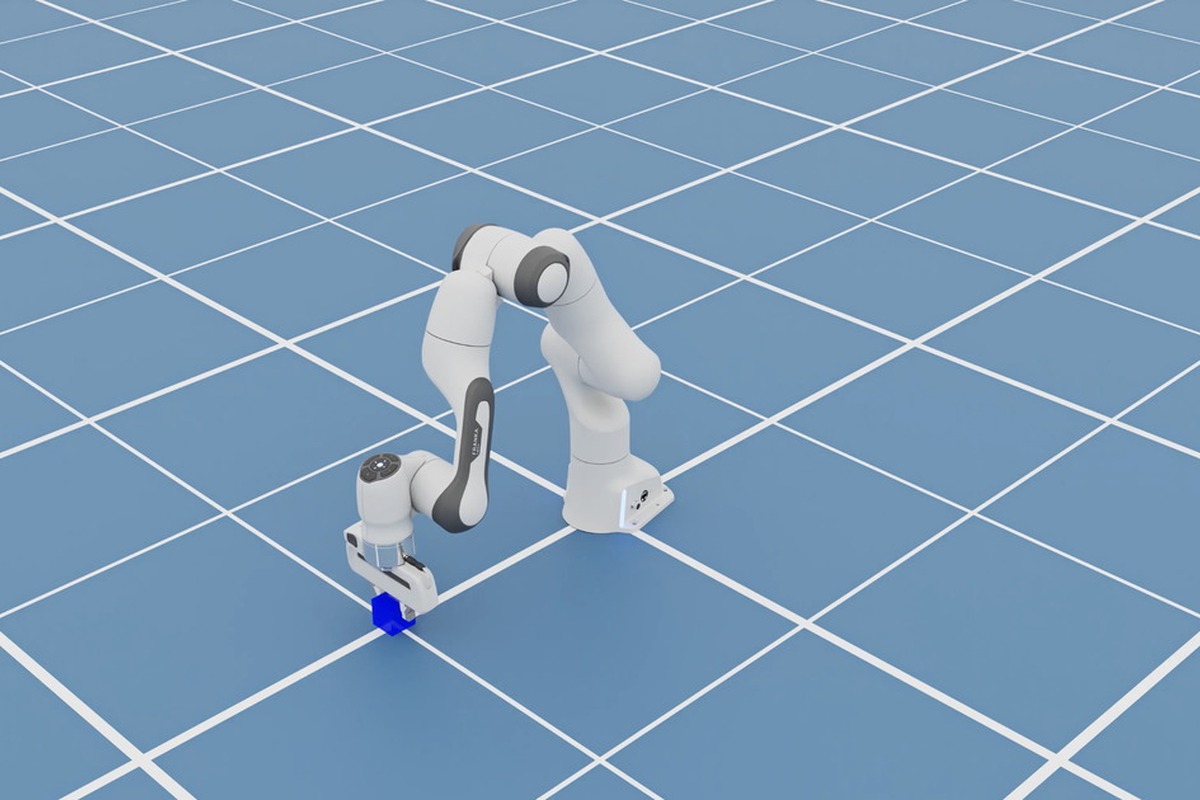
CoreWeave’s technical overview lists examples including Franka pick-and-place, warehouse scene generation and GPU-parallel reinforcement learning. Each tool also has a blank template for teams bringing their own workload.
That matters when an experiment changes. A team can vary a scenario or policy while retaining a known software environment, making it easier to compare runs without introducing unrelated configuration changes.
Finished Jobs and Useful Results Are Different
The service details distinguish execution status, recovered outputs and measured results. A job completing successfully does not establish that every scenario returned data or that a robot policy met its performance target.
Templates record inputs and return diagnostics so engineers can inspect what happened. CoreWeave also supplies agent skills and machine-readable interfaces for automating launches and result retrieval, while the engineering team remains responsible for deciding what constitutes a meaningful pass.
This builds on the development chain described in our Isaac platform coverage. RobotsBeat’s reporting on Amazon’s physical AI toolchain examines another cloud-based approach to coordinating robotics software and infrastructure.
Managed Access, With Validation Still Required
CoreWeave says the listed templates are available now through account-managed access. The product page directs prospective users to their account team rather than presenting an unrestricted public download or a universal fixed price.
The commercial proposition is less infrastructure work before an experiment begins. Whether it improves a particular program depends on workload compatibility, compute costs and the quality of the tests the team runs.
Simulation remains one stage of development. A successful virtual experiment can inform robot design and policy training, but deployment still requires validation against real hardware, sensor behavior and operating conditions.
Disclaimer: RobotsBeat is an independent media brand owned and operated by NuvexMedia LLC, publishing news, research, and insights on artificial intelligence, emerging technologies, automation, and related industries. NuvexMedia LLC invests in and collaborates with companies across the AI, Robotics, technology, software, and digital innovation sectors. These relationships do not influence RobotsBeat's editorial coverage, and the publication maintains full editorial independence to provide accurate, timely, and objective information. © 2026 NuvexMedia LLC. All rights reserved. This content is for informational purposes only and should not be considered legal, tax, investment, financial, or other professional advice.