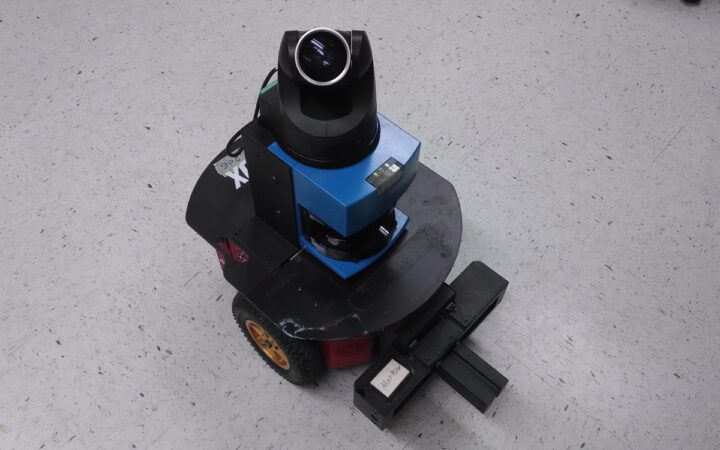
SLAM Explained: A Practical Guide to Robot Mapping and Localization
Learn how SLAM builds robot maps, how localization differs from navigation, and how to test drift, loop closure, sensor timing and recovery in real environments.
Explore RobotsBeat's latest reporting, research, and expert analysis tagged with "robotics sensors", collected in one continuously updated archive.
Learn how SLAM builds robot maps, how localization differs from navigation, and how to test drift, loop closure, sensor timing and recovery in real environments.
Understand encoders, cameras, lidar, IMUs and force sensors, and learn how calibration, timing and failure testing turn robot measurements into dependable actions.

Understand how robot vision works, when to use 2D or 3D sensing, and how lighting, calibration and error testing turn images into reliable production decisions.
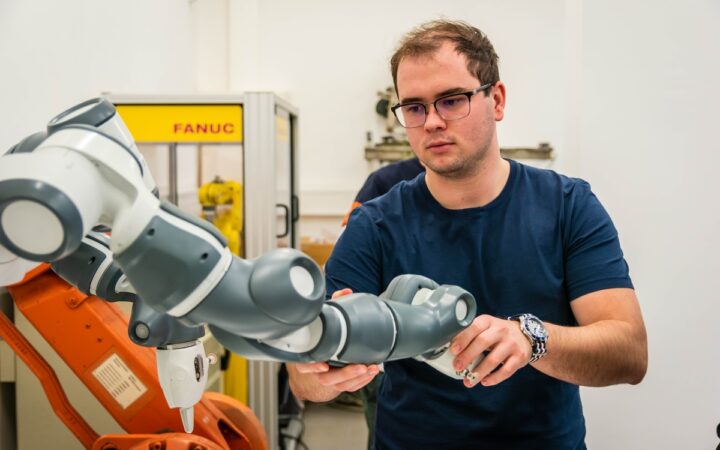
Learn how robot, tool, fixture and camera calibration fit together, then build independent accuracy checks and maintain reliable positioning through changes.
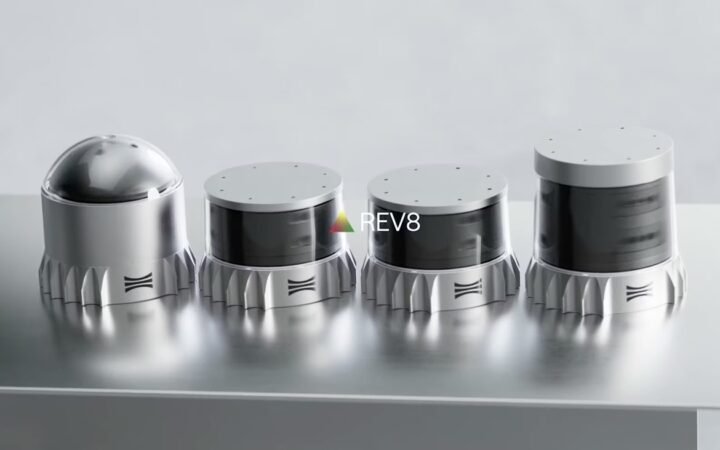
Ouster has launched Rev8, the world's first mass-produced native color lidar sensor, capturing 3D spatial and color data simultaneously on a single chip, eliminating the need for separate camera calibration…
Understand robot force control, impedance and compliance, then plan sensing, contact behavior and validation around reliable physical results.
Learn how robot actuators combine motors, gearing, feedback and control, with practical load calculations and tests for speed, heat and repeated operation.